Jul 2026 · Solo · MEMS sensor challenge
Pedestrian Dead Reckoning (Phone IMU)
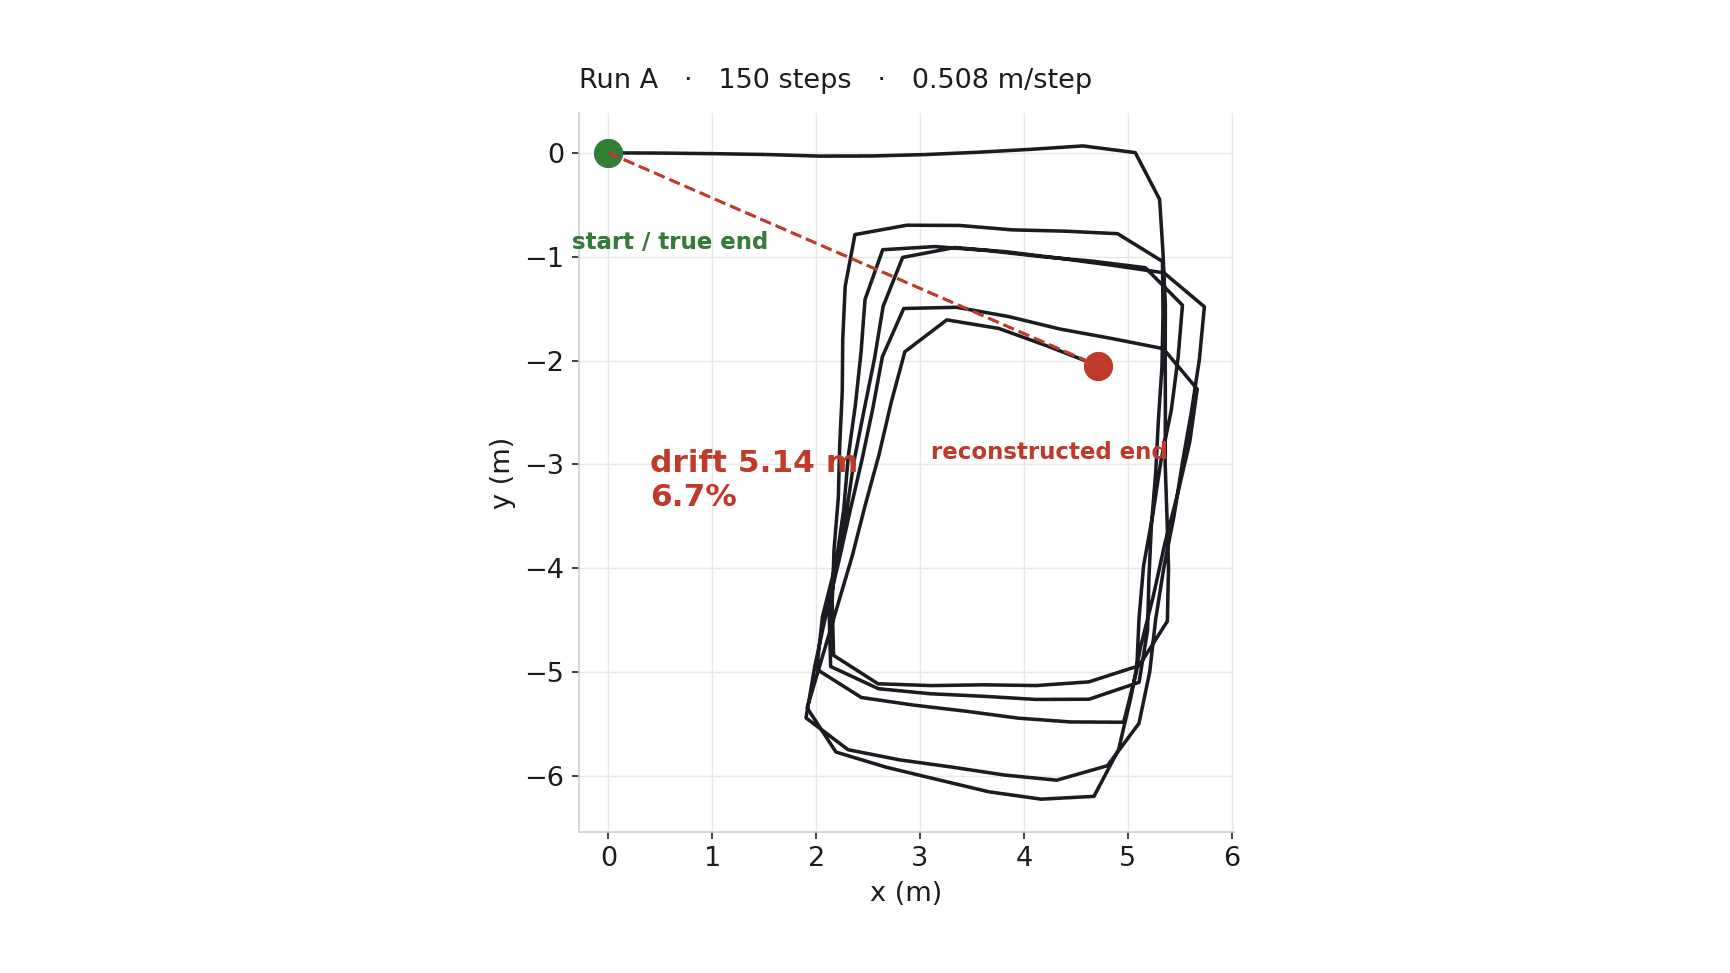
A phone IMU can tell you how fast you are accelerating and how fast you are turning, but not where you are. Getting position out of it means integrating, and integrating noisy, biased sensor data compounds the error. That accumulating error is drift, the central unsolved problem in inertial navigation. I built this to measure it: walk a route with known ground truth using only the accelerometer and gyroscope, reconstruct the path in Python, and see how far off it lands.
PythonNumPySciPypandas
View details →